How Runtime introduced robots that learn in simulation on X
Robot policies that learn in simulation and transfer to real hardware
What Runtime launched

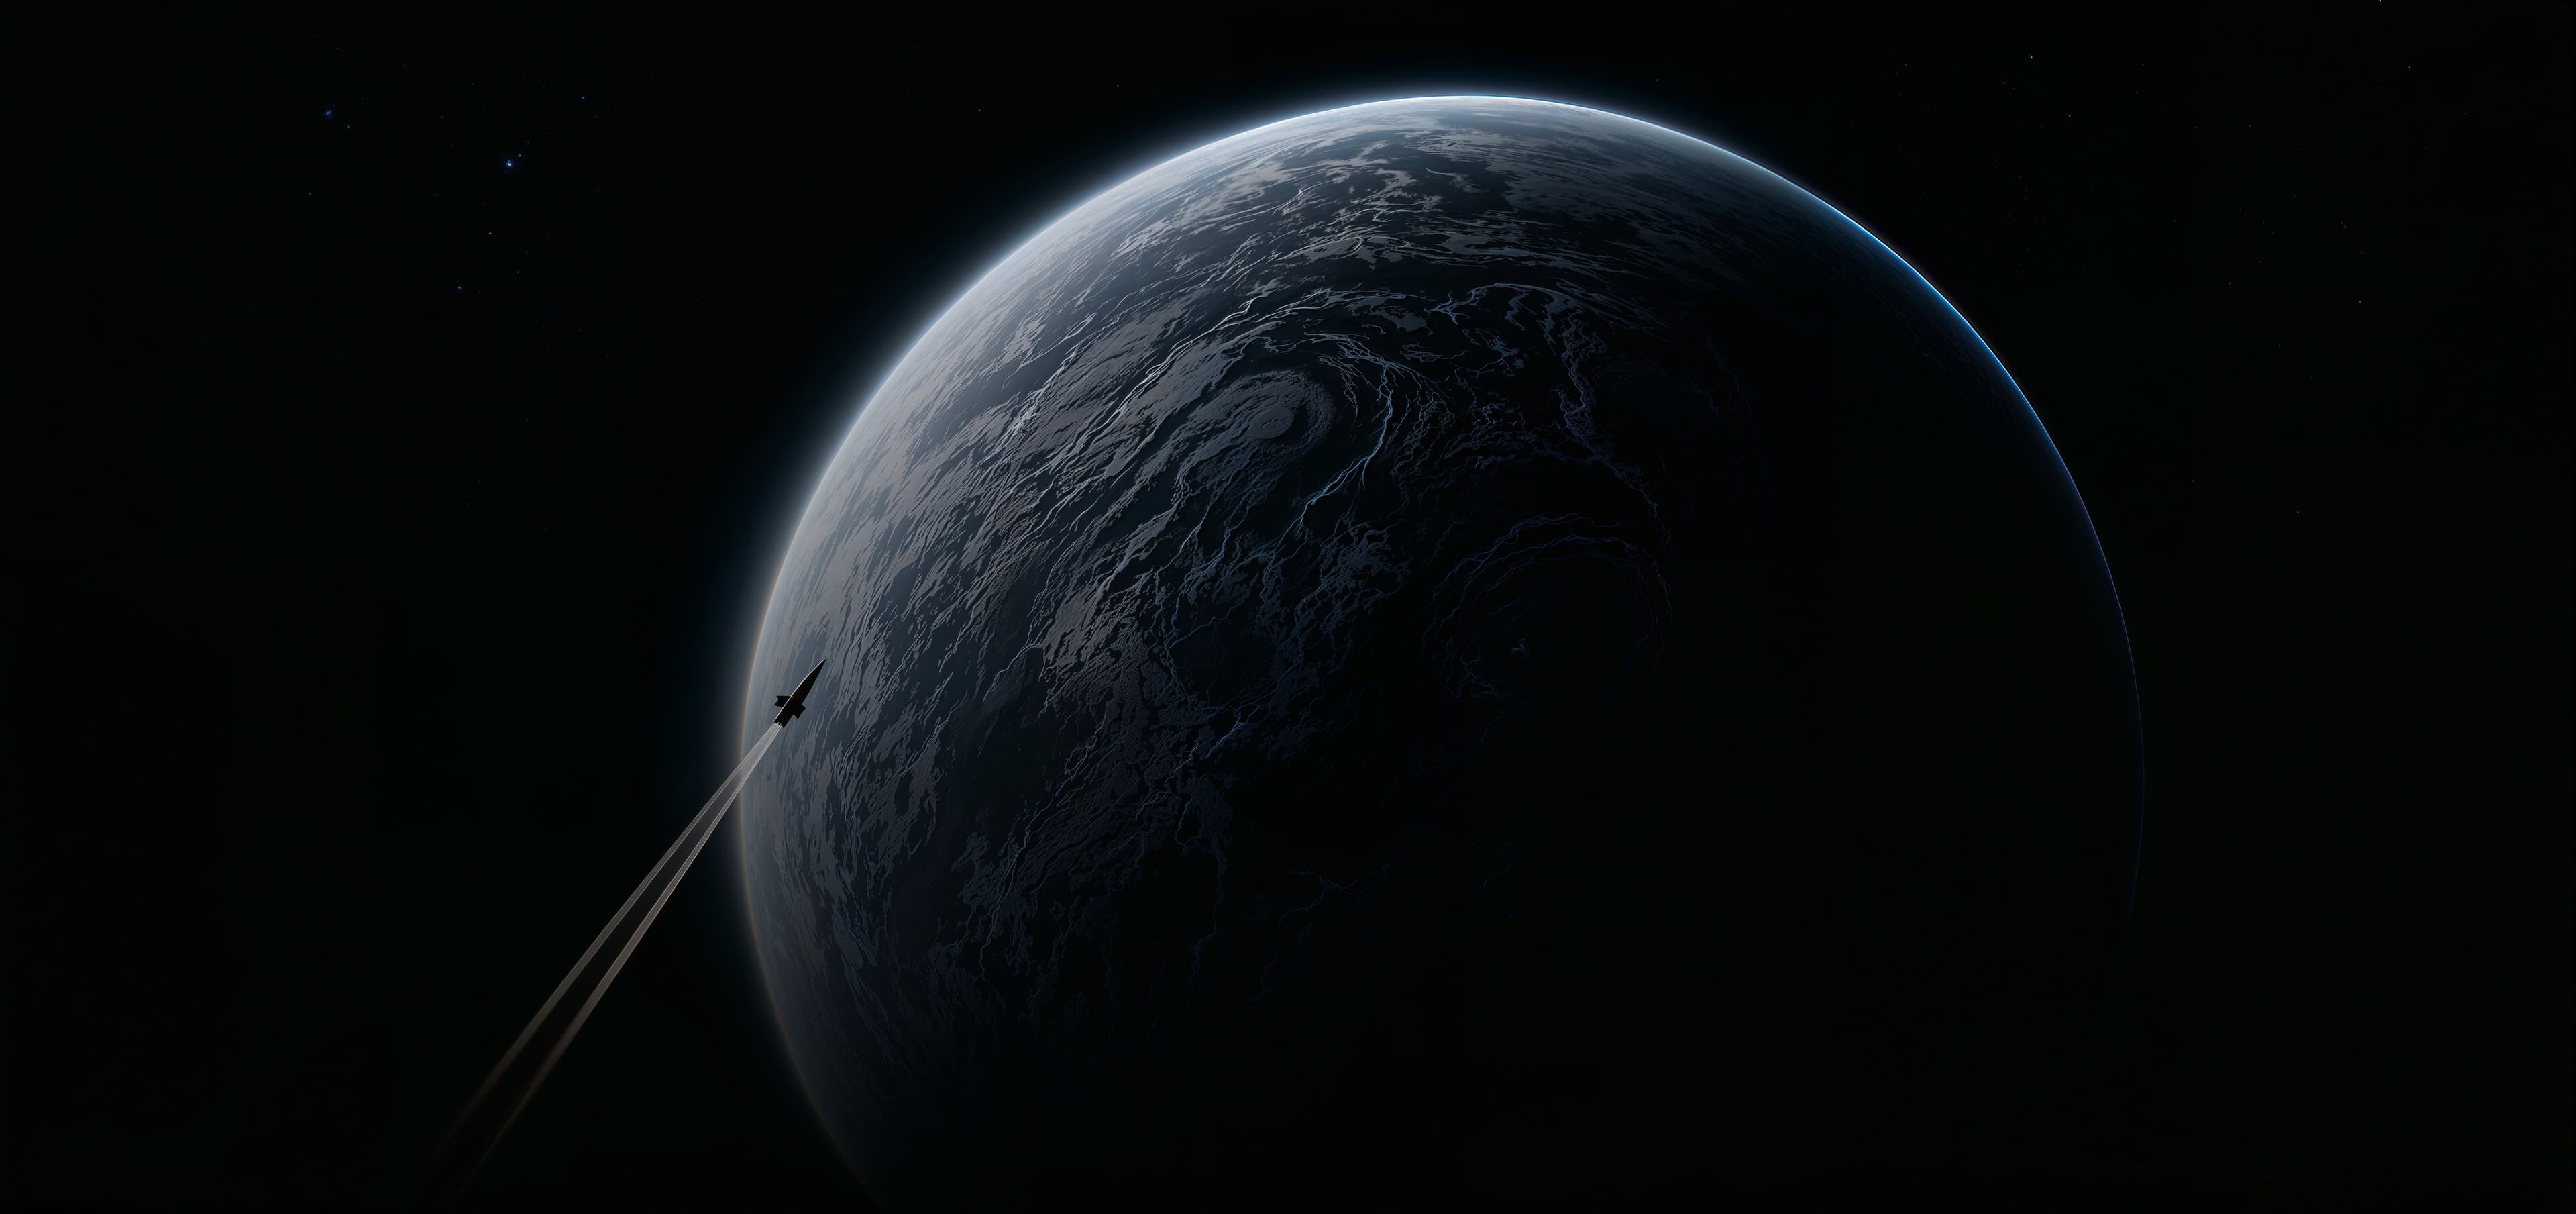
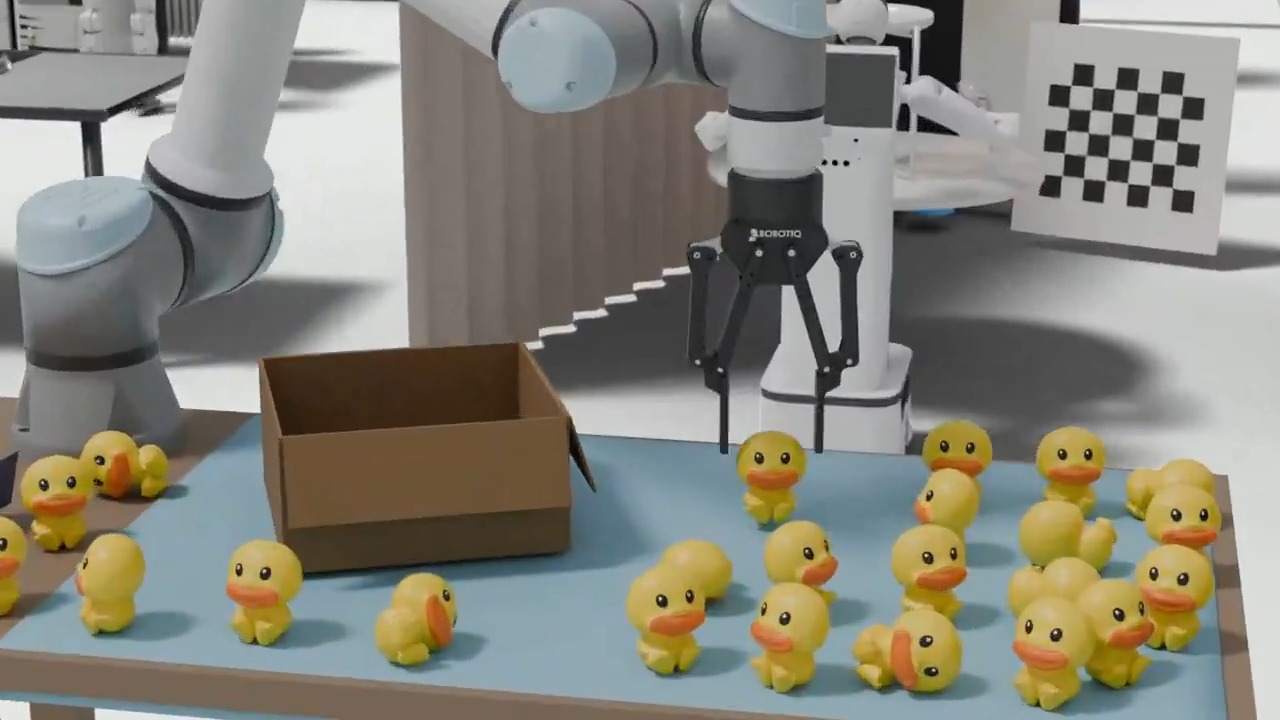
Robots shouldn't need to be fine-tuned for every new task. Introducing Runtime (YC F26). We're reimagining robot policies: explore in simulation, then act in the real world. Watch it thread a rope. No fine-tuning. No teleoperation. https://t.co/Qik34e5XIy
How TLVC rated the launch
TLVC Rating
About the launch
Runtime (YC F26) is a robot policy for teams deploying robots that still need a new fine-tune or a teleoperation session for each task. It turns what the robot sees into a simulation, searches options there, acts on the one that works in the real world, and keeps the simulation in sync with the scene. The launch is aimed at companies putting more robots into the field, at a point when the founders say simulation is fast and accurate enough to guide action, not only training and evaluation. The launch video shows a robot threading a rope with no fine-tuning and no teleoperation. Runtime says its experiments match or beat leading robot foundation models on real tasks including rope threading and egg grasping. The company is now speeding that loop so it can run live, and early access opens in January. Liam Zhong, Yim Ying, and Chen Peng founded the San Francisco company out of the University of Pennsylvania. They describe the group as coming from Penn's GRASP Lab, with experience in computer vision, control, reinforcement learning, and robot foundation models, and with papers and reviews at CVPR, ECCV, and NeurIPS. Zhong is co-founder and CTO.
Tags
Questions
Frequently asked questions
The Runtime launch post reached 221K views on X, with 592 likes, 27 reposts, 57 comments, 135 bookmarks.
Runtime launched on X on November 5, 2026 with the message "Robot policies that learn in simulation and transfer to real hardware".
Runtime (YC F26) is a robot policy for teams deploying robots that still need a new fine-tune or a teleoperation session for each task.
Launchvideo.com rated the Runtime launch 3.40 out of 5: hook 3/5, editing / creativity 2/5, copy 5/5, sentiment of launch 4/5, distribution strategy 3/5.